Robotics & Autonomous Systems

Jorge Ramirez

I’m a computer engineer building robotic systems from software to hardware, and the controls, perception, and planning that hold them together.

Stack
Python · C++ · ROS2
Education
M.S. EE · B.S. CPE · Cal Poly SLO
Status
Open to opportunities
Contact
01

Projects

AUTONOMOUS GROUND VEHICLE

Planning & Control for Autonomous Vehicles

A complete autonomous ground vehicle software/hardware stack covering controls, planning, and perception.

Controls EKFs CV Planning Occupancy Grid Mapping Jetson Orin Nano Quanser QCar Quanser Sim Intel RealSense LiDAR IMU AVs OpenCV
Approach
  • State estimation & modeling — modeled vehicle kinematics with a bicycle model and fused GPS/IMU data through a dead-reckoning and heading-corrected EKF for robust pose estimates.
  • Control — closed the loop with longitudinal speed control and Stanley-based geometric steering for trajectory tracking.
  • Perception (vision) — calibrated cameras for undistorted imagery, then layered lane detection, object detection (YOLOv8), and bird's-eye-view lane-keeping with pure-pursuit control.
  • Perception (LiDAR) & planning — built occupancy grid maps from LiDAR for environment interpretation, and planned global paths with A*.
PLANNING & CONTROL STUDY

A* vs. Hybrid A* — CARLA Demo

Simulator demo comparing Hybrid A* and A* for autonomous vehicle applications.

CARLA Simulator Python AVs Path Planning
Approach

This project is a demonstration between A* and Hybrid A* path planning for autonomous parking in CARLA. Both planners were sourced from an open source motion planning library, with the main project contribution being the integration of the planners onto a testing framework within CARLA. This includes building a CARLA obstacle pipeline from vehicle bounding boxes and a custom path follower as CARLA does not support custom path tracking. A Stanley controller with a PID longitudinal control was tuned to match the built-in CARLA Audi e-tron model. Thus offering a closed loop setup from planning to tracking to demonstrate the kinematic feasibility gap between the planners.

ROBOTIC MANIPULATION

Vision-Based Robotic Manipulation

Implemented a vision-guided robotic manipulator pick-and-place sorting system.

CV Planning Controls Manipulators Intel RealSense OOP OpenCV Open Manipulator-X
Approach

Built a vision-guided pick-and-place system on an Open Manipulator‑X arm, using an Intel RealSense camera to detect colored spheres via Hough Transform circle detection and HSV-based color classification. Ball positions were localized by repurposing an AprilTag PnP pipeline to get camera-frame coordinates, then transformed to robot frame using a calibration matrix from an earlier lab. Each pick used four chained cubic trajectories (approach → descend → retract → deliver to bin), with the gripper timed to close and open at the grasp and drop points.

Design Decisions
  • Hough Transform over contour analysis — justified by known, well-defined circle geometry, despite the higher memory cost.
  • Cubic trajectories over PID control — ball positions were static, so smooth open-loop trajectories were sufficient; PID would only have been necessary for a dynamic environment.
Code Summary

Image pipeline: HSV conversion → grayscale + CLAHE contrast enhancement → Gaussian blur → Hough circle detection → HSV-hue color classification, with workspace-bounds filtering to reject false-positive detections outside the robot's reachable area.

AUTONOMOUS AERIAL SYSTEMS

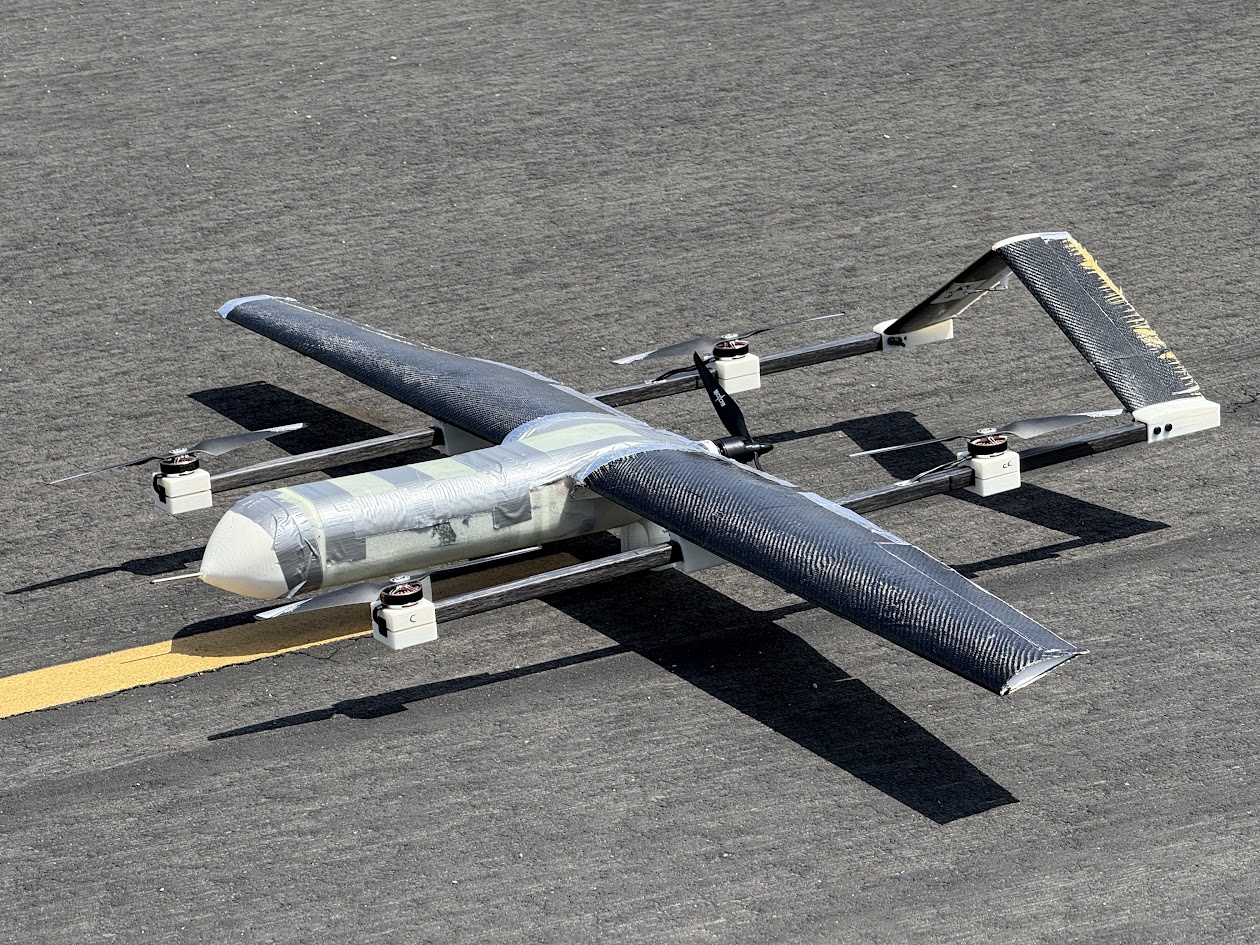
NGCP — Avionics Lead, Autonomous VTOLs & Aerial Vehicles

Lead and developed avionics for custom autonomous drones, fixed wings, and VTOLs.

Autonomous Vehicles Hardware PX4 ArduPilot Avionics Motors Jetson Orin Nano Raspberry Pi
Program Context

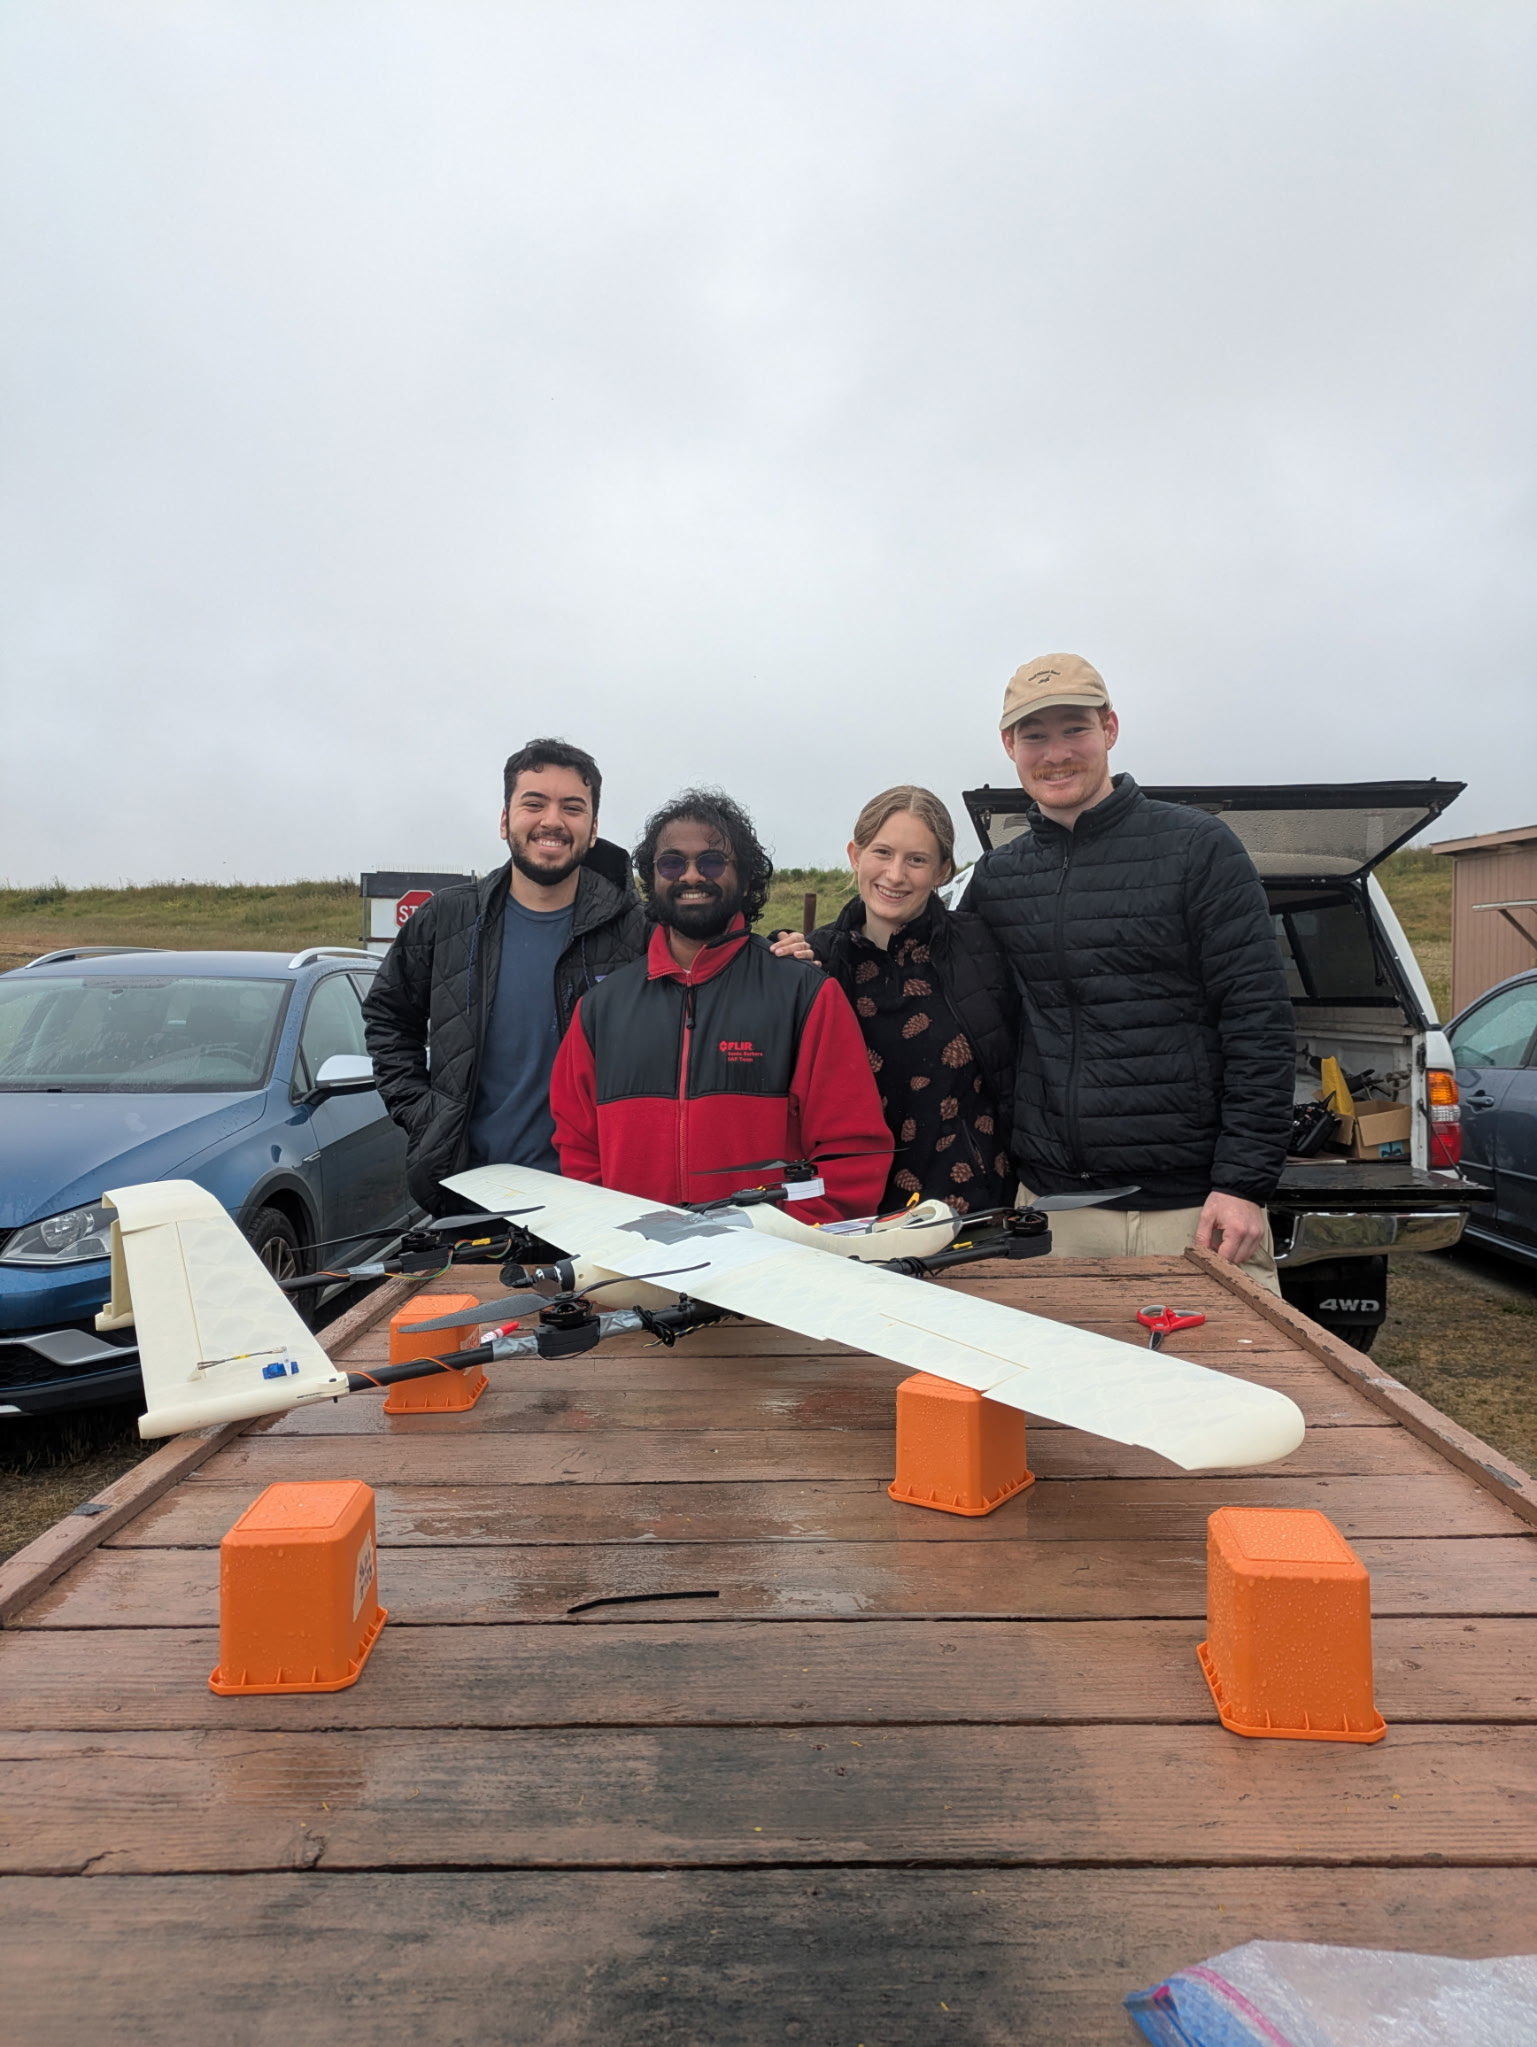
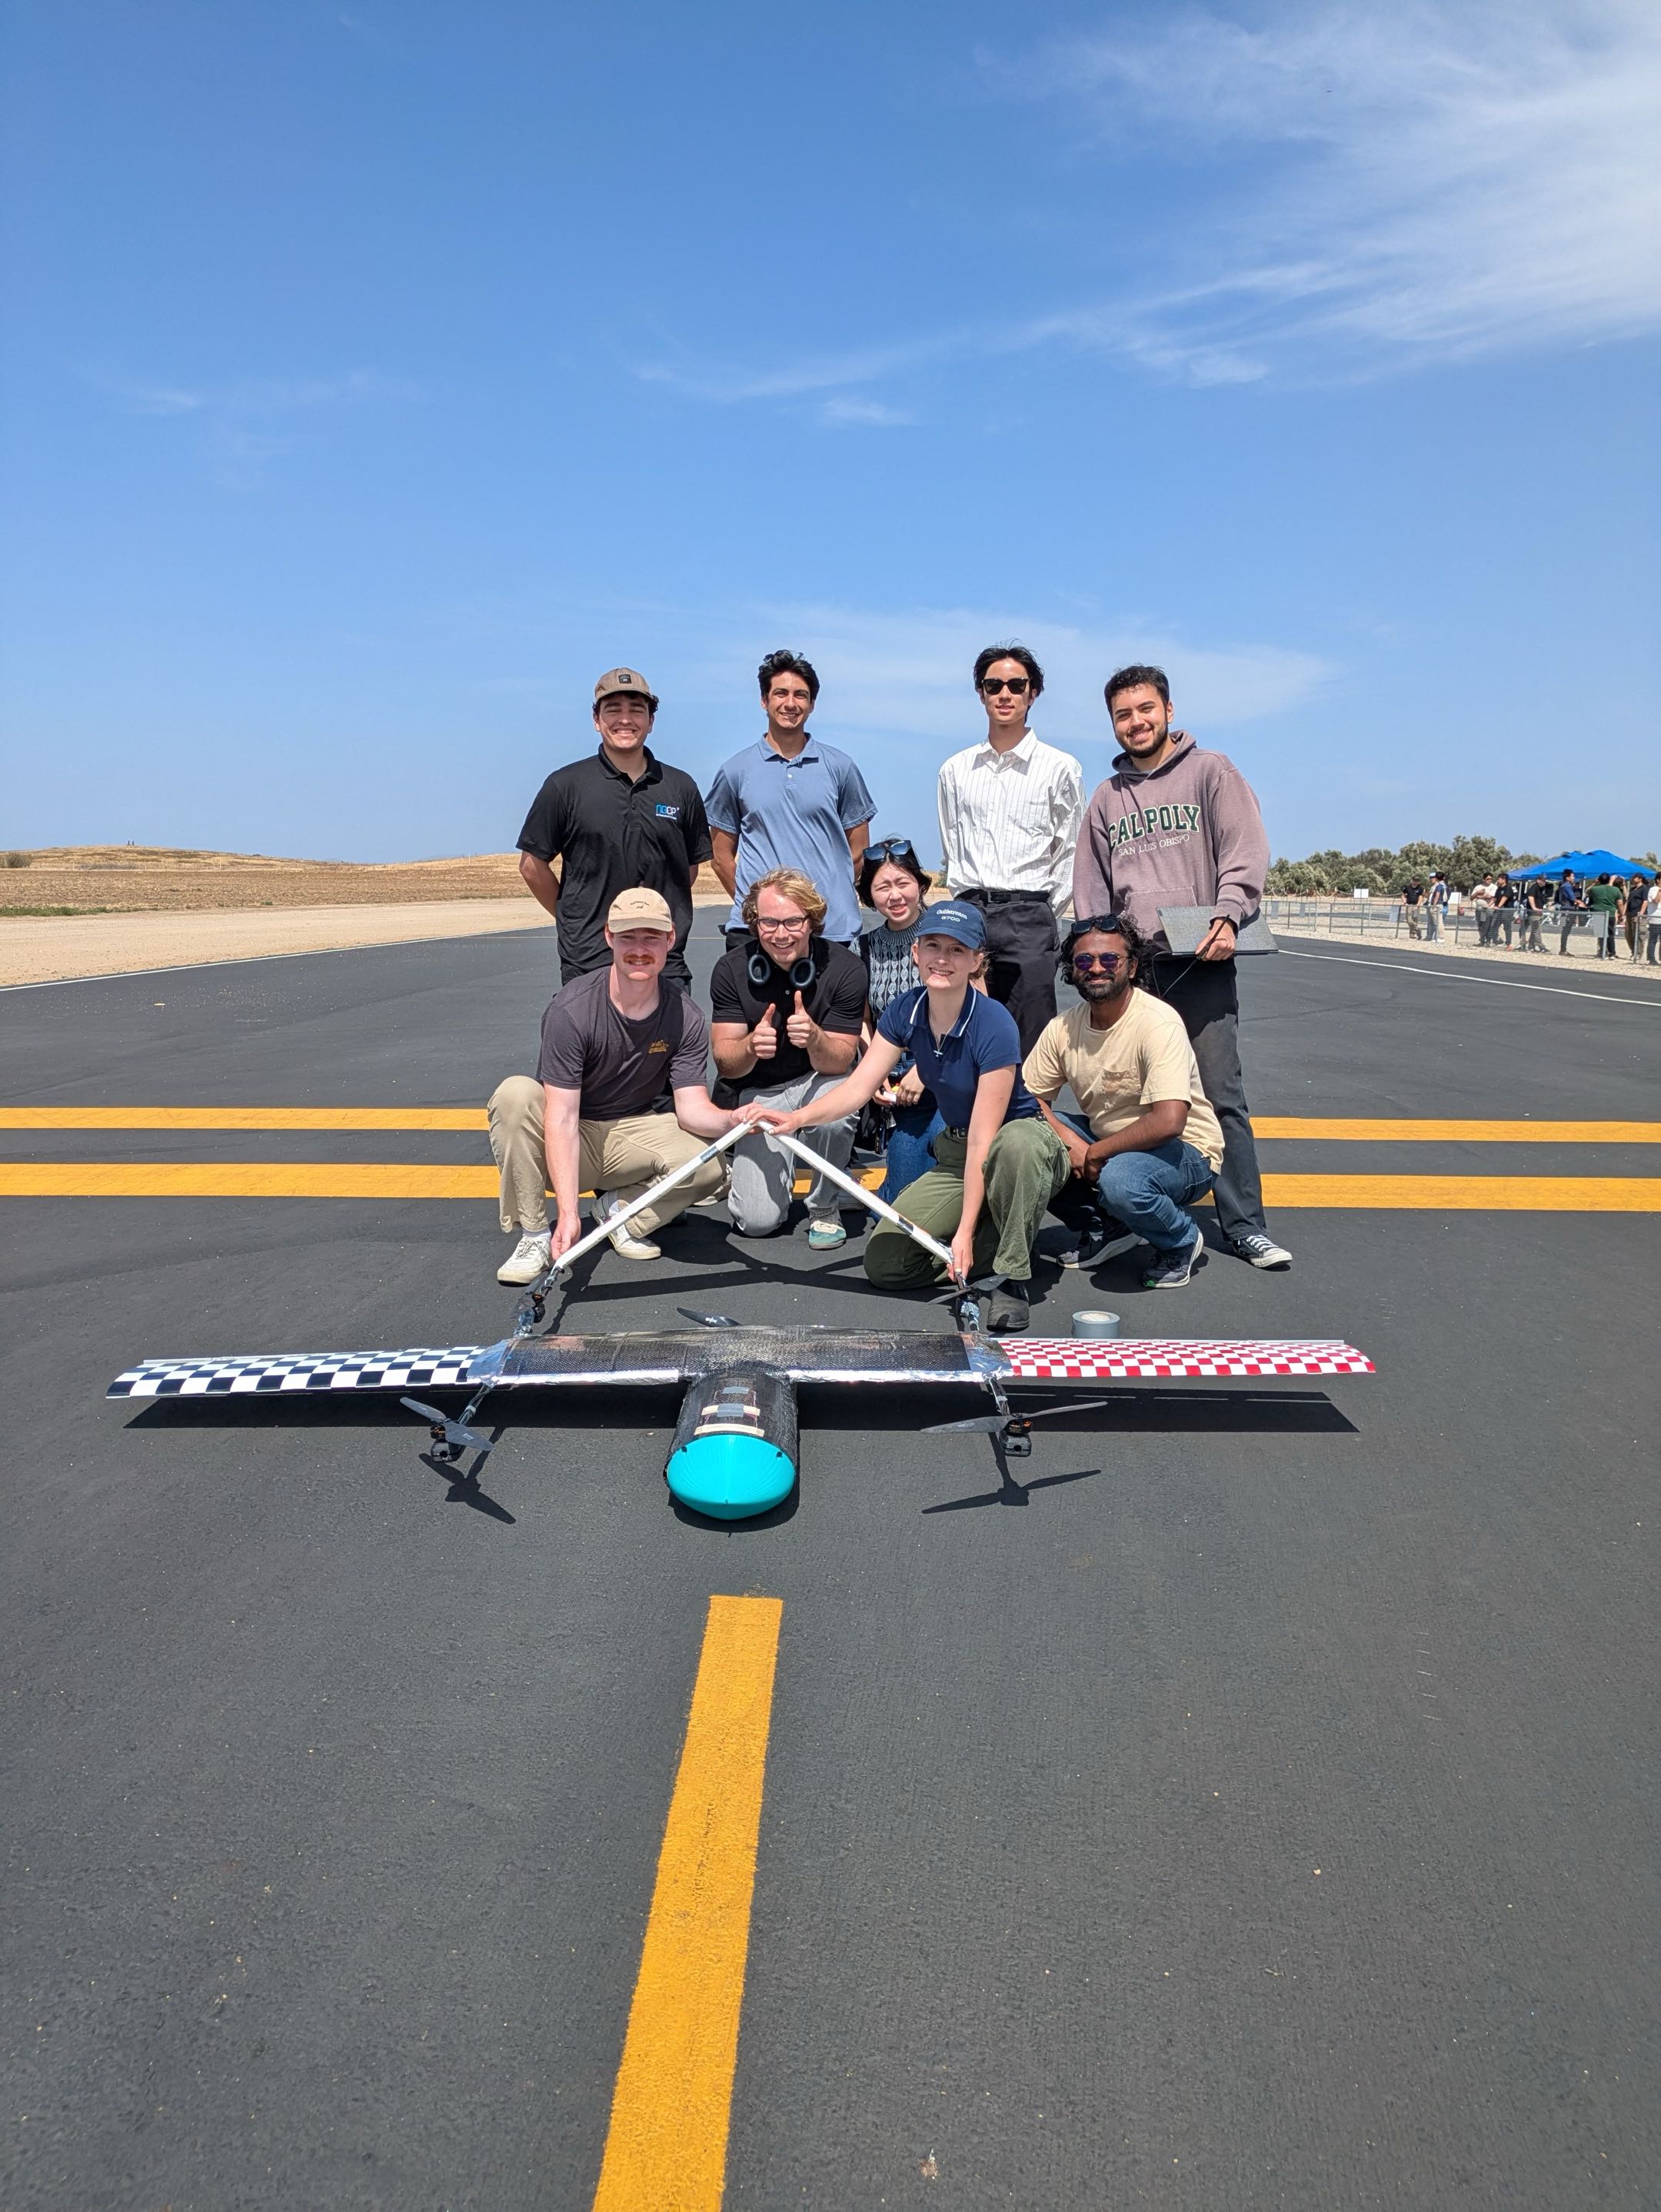
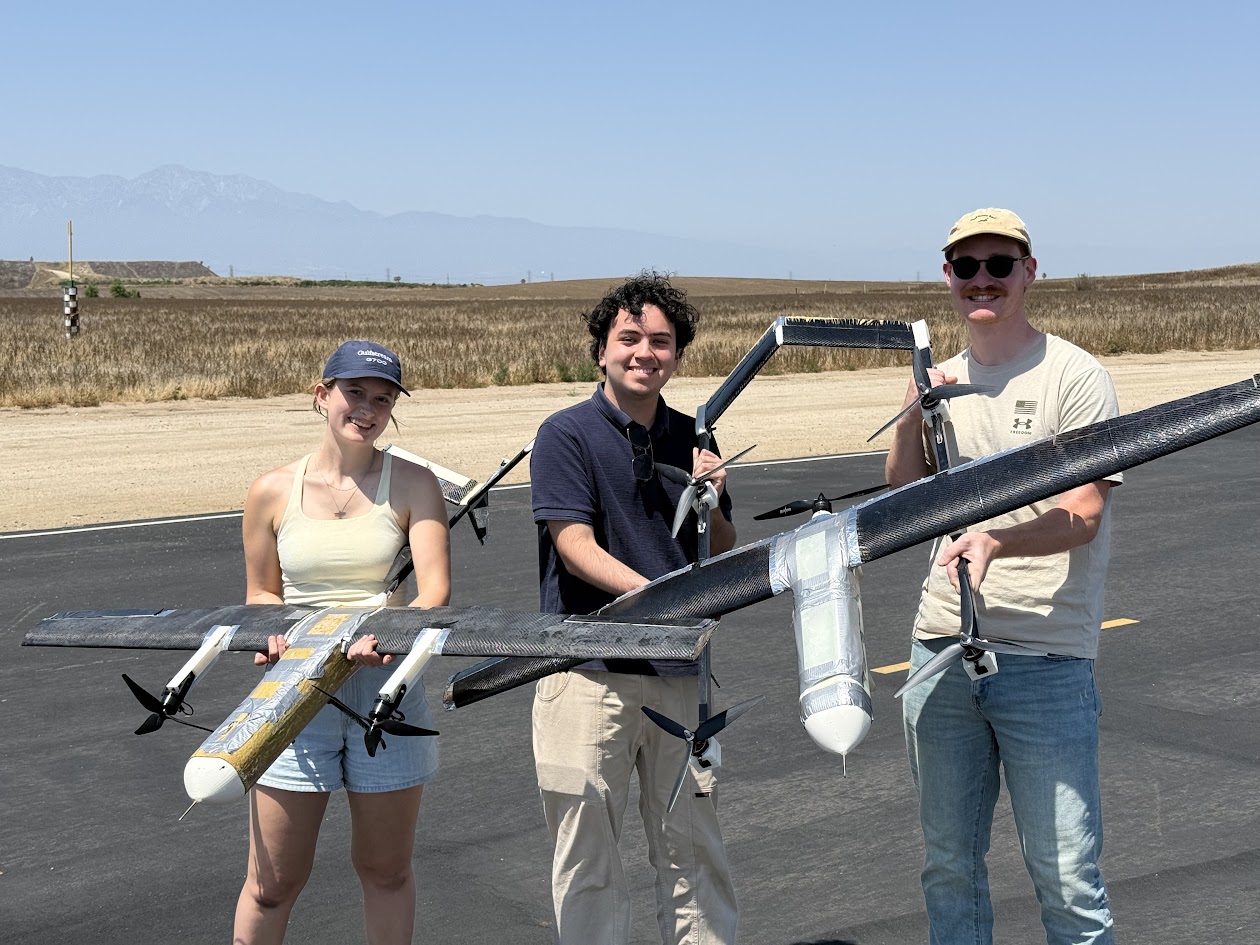
The Northrop Grumman Collaboration Project (NGCP) is a year-round autonomous aerial vehicle program sponsored by Northrop Grumman where Cal Poly SLO collaborates with Cal Poly Pomona to complete varying flight missions. The project runs on a 1 year cycle of research, design, and build that ends in a live autonomous flight demo in front of officials. Over 3 years I progressed from embedded team member to Avionics Lead.

Approach

Owned the full avionics stack across multiple airframes (hexcopter and quadcopter drones, fixed-wing aircraft, and both standard and tilt-rotor VTOLs). My work spanned hardware selection via trade studies and FMEAs, electrical and power system analysis, flight software configuration (PX4, ArduPilot, QGroundControl), and hands-on electronics integration and troubleshooting, plus leading the avionics team through each year's design-to-demo cycle.

Platforms Built

Hexcopter · Quadcopter · Fixed-Wing · Standard VTOL · Tilt-Rotor VTOL

Results

In the final year, led avionics through a successful demo day launch of two autonomous aircraft, a standard VTOL and a tilt-rotor VTOL, with both completing their assigned flight missions fully autonomously.

MECHANICAL CONTROL SYSTEM DESIGN

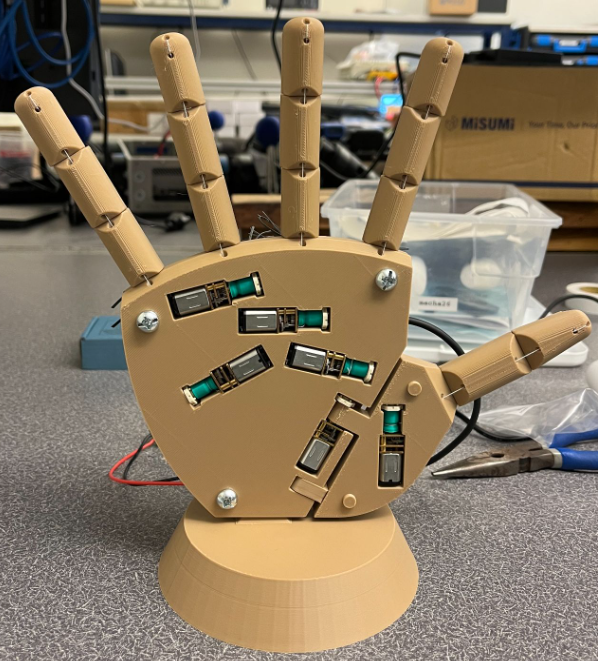
Teleoperated Robotic Hand

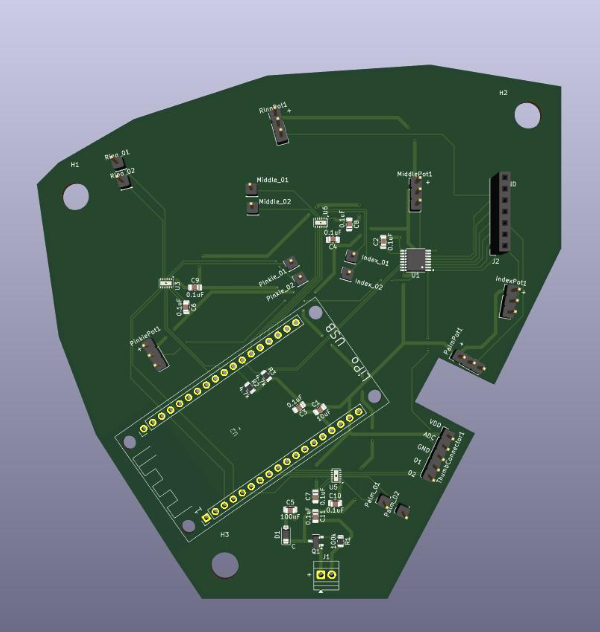
Teleoperated robotic hand with custom PCBs using RTOS.

3D-printed robotic hand with servos installed
Custom PCB layout in KiCad
PCB Design ESP32 RTOS KiCad Control Systems Embedded
Approach — System Overview

Designed a teleoperated robotic hand that mirrors human finger movement in real time with a glove integrated with flex sensors that captures the operator's hand pose, and small servo motors drive the corresponding fingers on the robotic hand. The project spanned the full research, design, and prototyping/testing cycle for a mechanical control system.

PCB Development

Designed a custom PCB adapting off-the-shelf motor driver circuitry into a board built around an ESP32 microcontroller, laying out the traces and wiring to integrate driver ICs, power distribution, and microcontroller I/O.

System Design — Communication & Control Loop

Both the glove and the robotic hand run their own ESP32, communicating wirelessly over ESP-NOW. Each ESP32 is programmed with FreeRTOS to guarantee deterministic timing across three concurrent tasks: reading encoder feedback, running per-finger PID control loops, and receiving pose data from the glove — deterministic scheduling was essential to keep sensor reads, control updates, and wireless comms from drifting out of sync.

02

About

Hi, my name is Jorge and I am a quick thinking and hands on engineer. I learn best through not only understanding concepts, but applying them to real world problems. Doing all these projects scratched the same itch that building Legos did for me as a kid, and I have continued being involved in robotics since then. Some of my hobbies include watching movies, playing pool, and learning the guitar. Feel free to reach out if you have any questions or just want to talk!

Favorite Films

For those who really like movies my letterboxd is jjrzov

Good Will Hunting
Rushmore
Speed Racer
The Holdovers